60 V BLDC motor controller
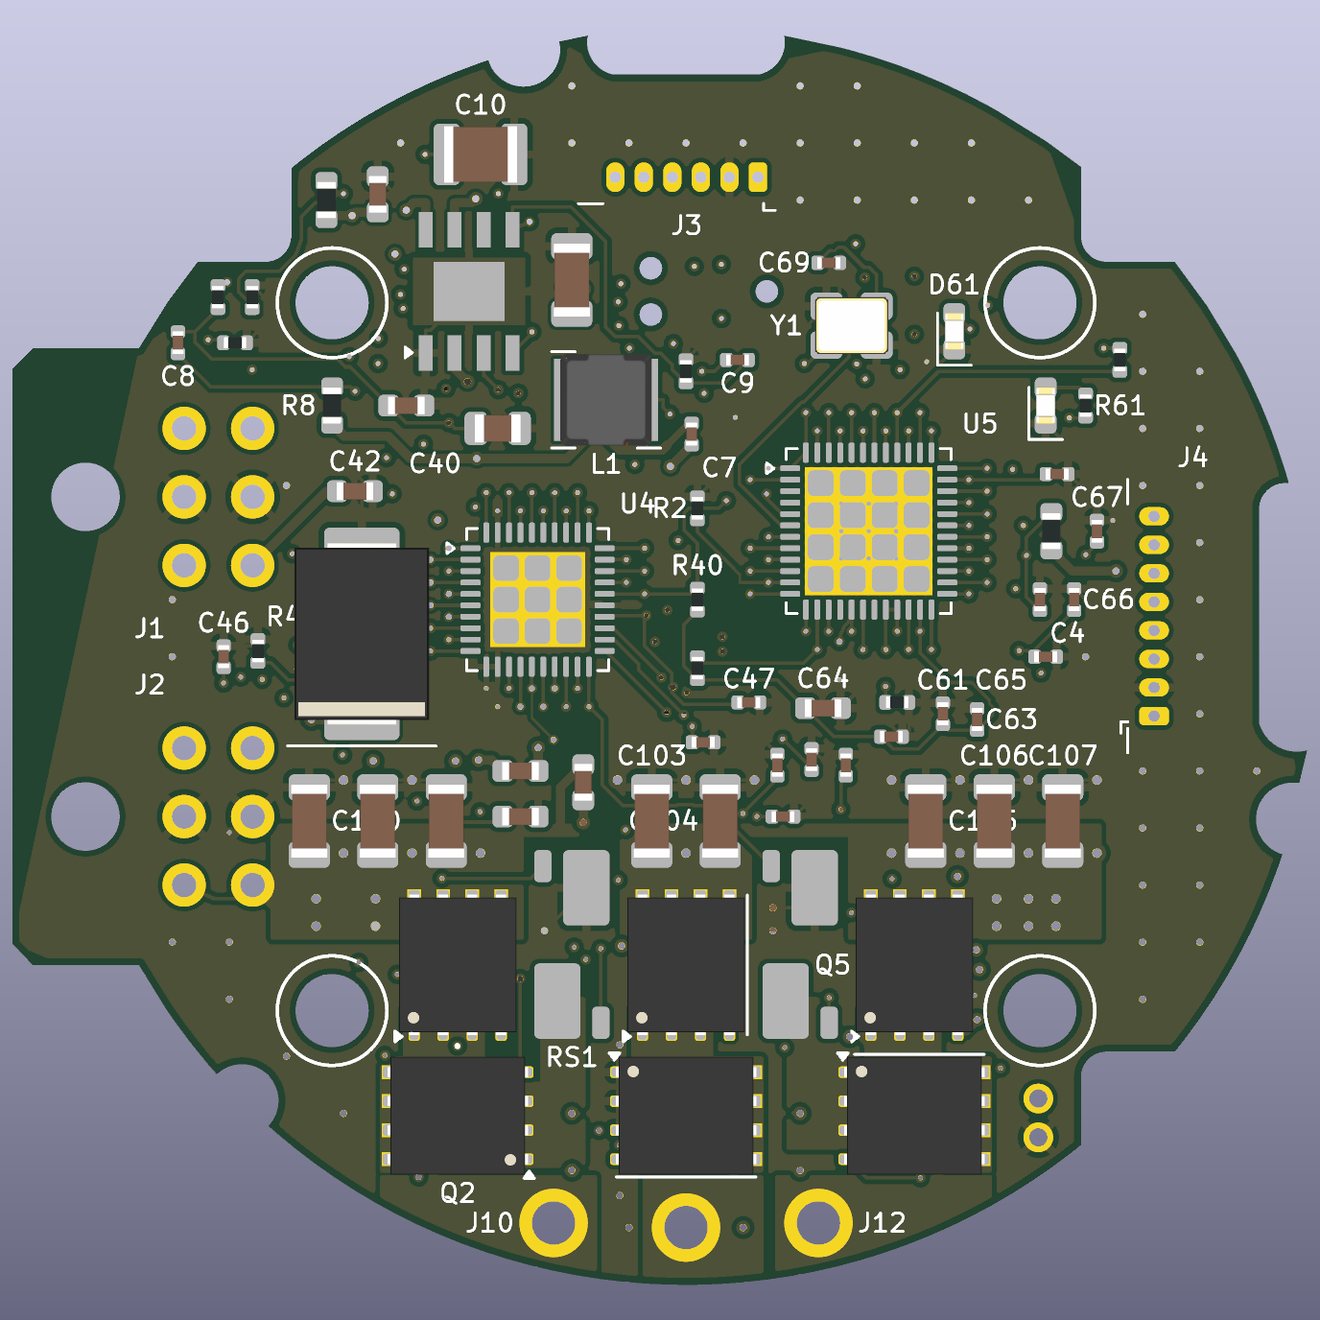
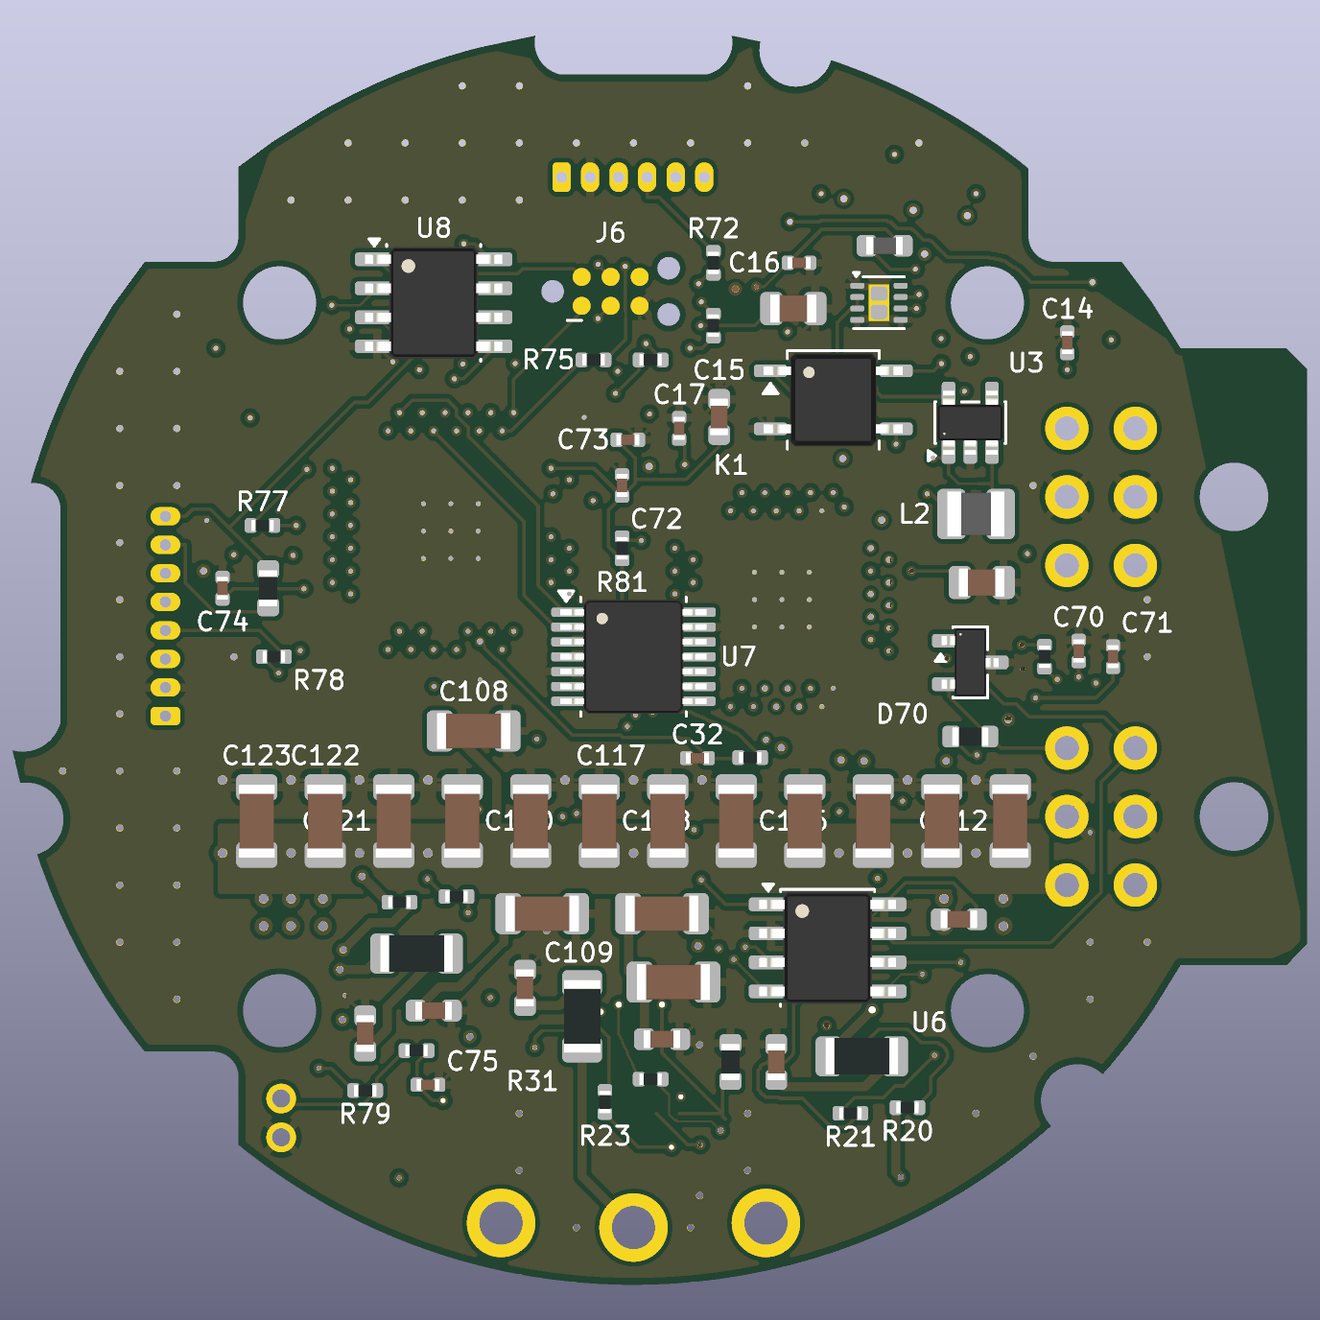
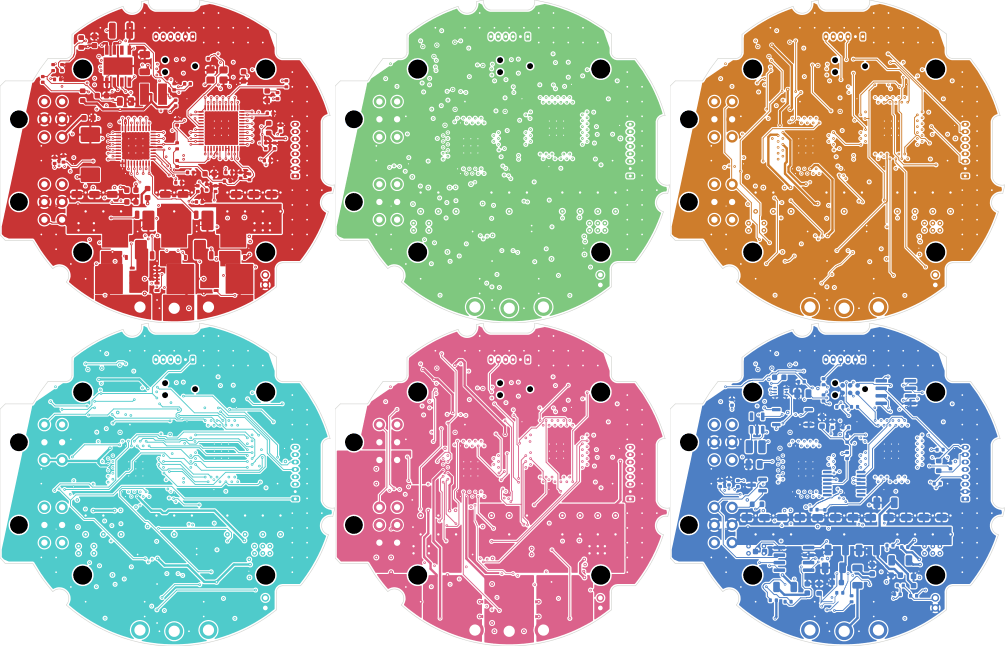
I routed a six-layer, 55 mm BLDC motor-controller board in KiCad 10. It targets a 60 V maximum bus, 20 A continuous and 80 A peak, using the MAB Robotics MD80 mounting, connectors and encoder position. It has not been fabricated, and firmware has not started.
A TI DRV8353 gate driver runs six Infineon 100 V MOSFETs in 5 × 6 mm packages, with two 0.5 mΩ shunts on the top side between the FETs. An STM32G474 runs field-oriented control and talks CAN-FD, and an AS5047P reads the rotor angle on-axis. A 100 V buck, a 5 V buck and an LDO make the logic rails, and a 5.0SMDJ60A TVS holds a 60 V hot-plug below the parts' 100 V rating.
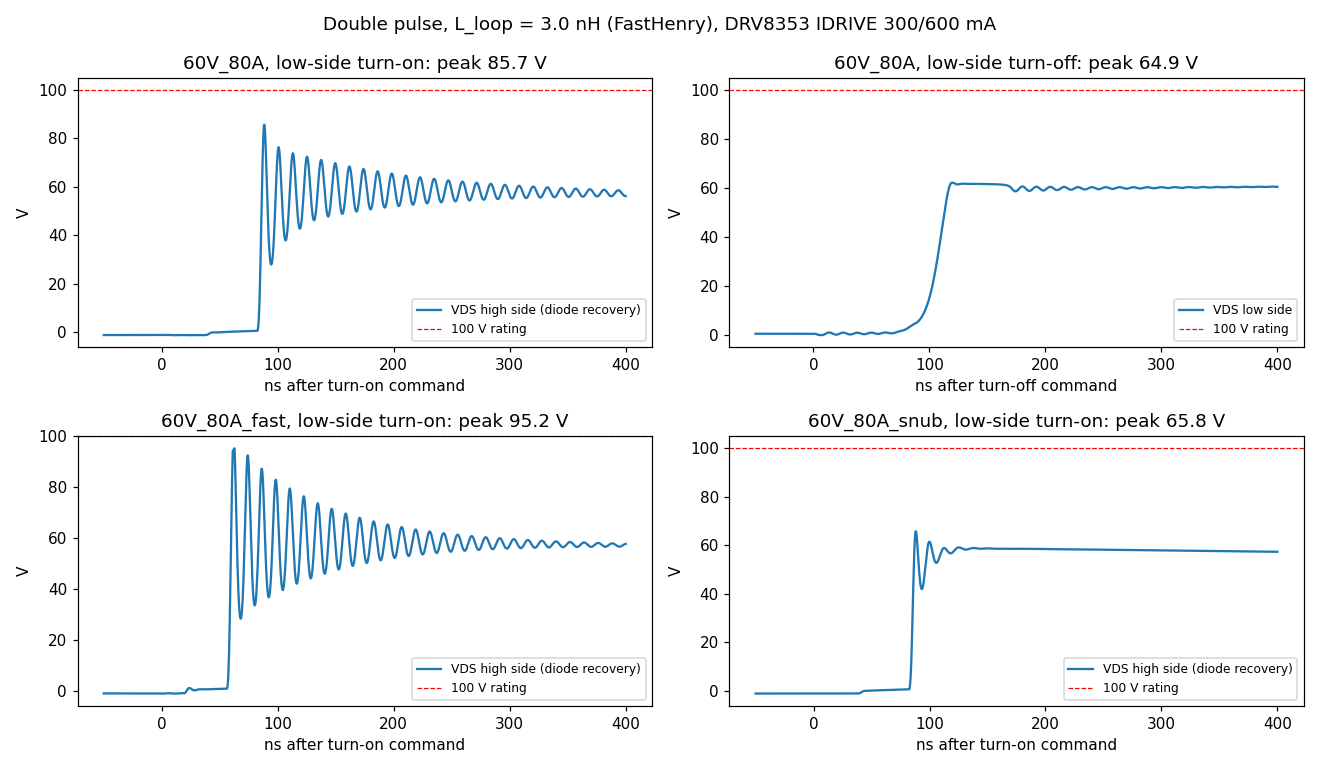
The outline, holes and connectors match MAB's STEP model to 0.000 mm, and the board has no unconnected nets. FastHenry estimates a 3 nH commutation loop; LTspice double-pulse runs predict a worst switching peak of 85.7 V. Current, loss and thermal limits need hardware measurements.