← Darsh Patel

3 lb combat robot

Aggie Robotics · Combat electrical team

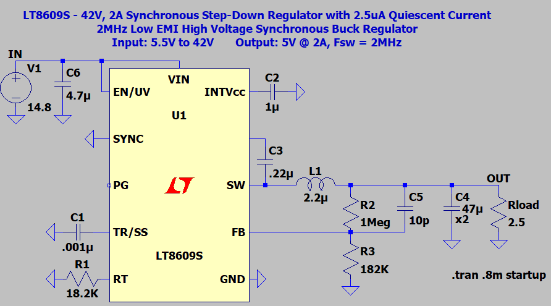
I led the electrical architecture for a 3 lb combat robot. I simulated the LT8609S buck regulator in LTSpice and specced parts for purchase.

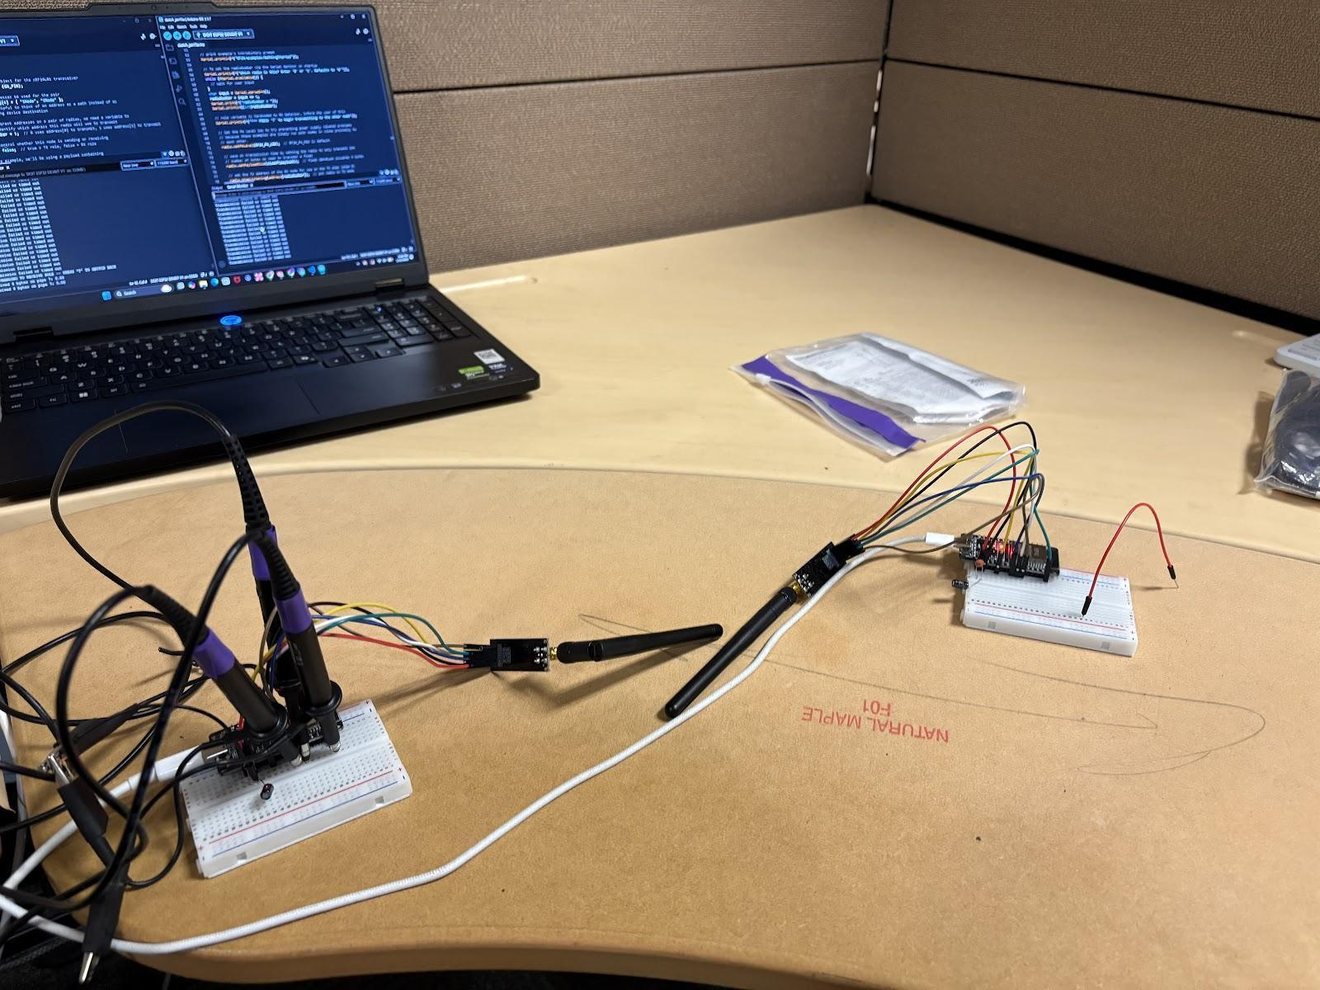
When the radio link failed, I probed SPI between the ESP32s and nRF24L01 radios on a scope, using test experience from my internship. I checked decoupling and inspected RX FIFO registers to isolate the fault. The link later moved to ESP-NOW.
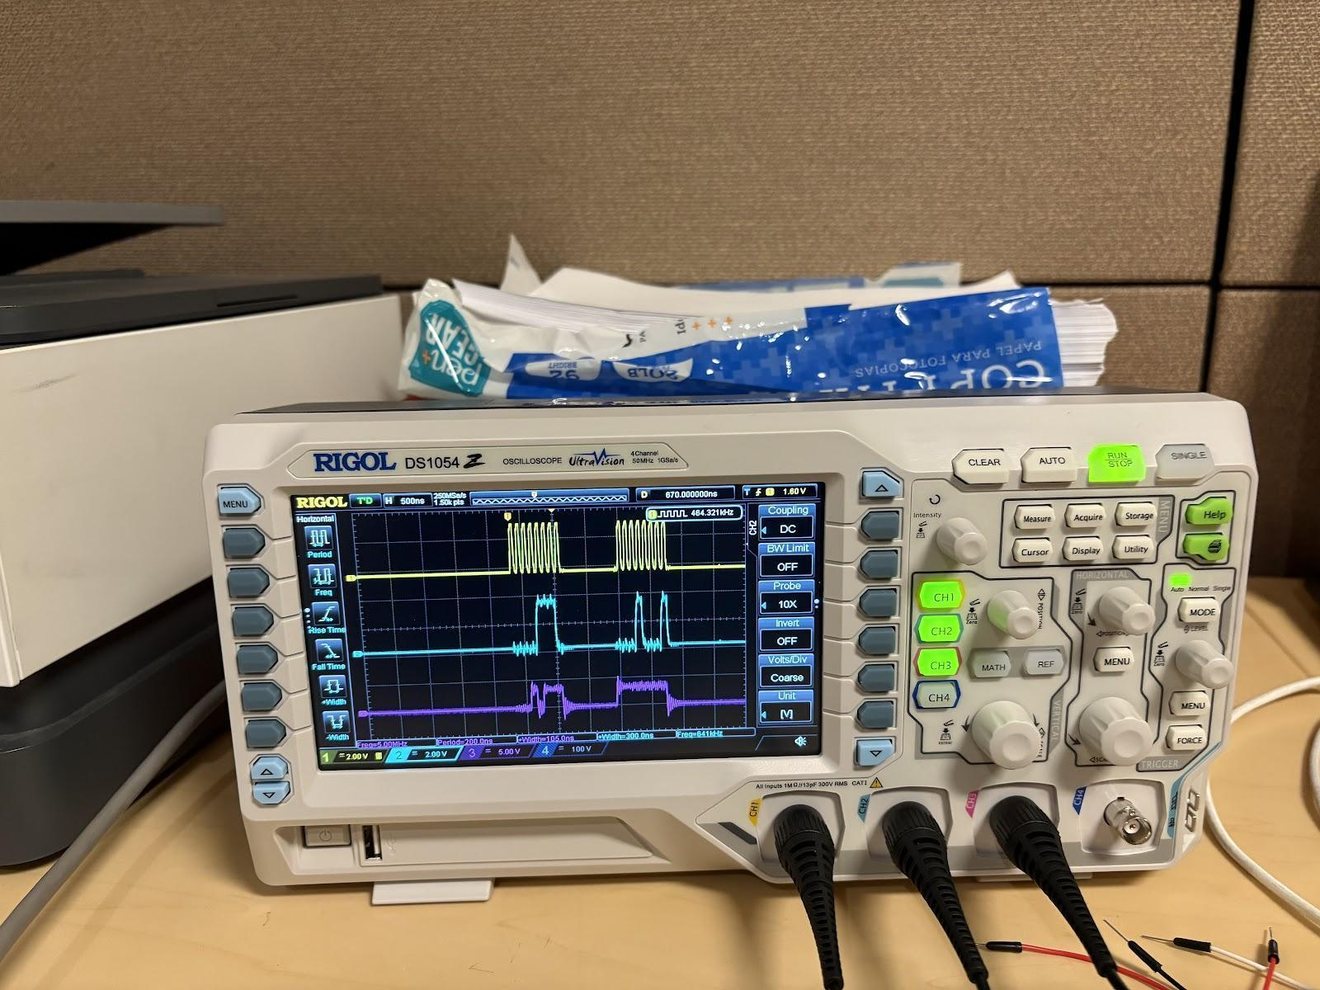
Debugging the radio link: SPI clock, data and chip-select between the ESP32 and nRF24L01, captured on a Rigol scope.
The ESP32 and nRF24L01 radios on breadboards, with scope probes on the SPI lines and firmware open on the laptop.
LTSpice startup simulation of the LT8609S buck regulator, stepping the 14.8 V battery down to 5 V at 2 A.