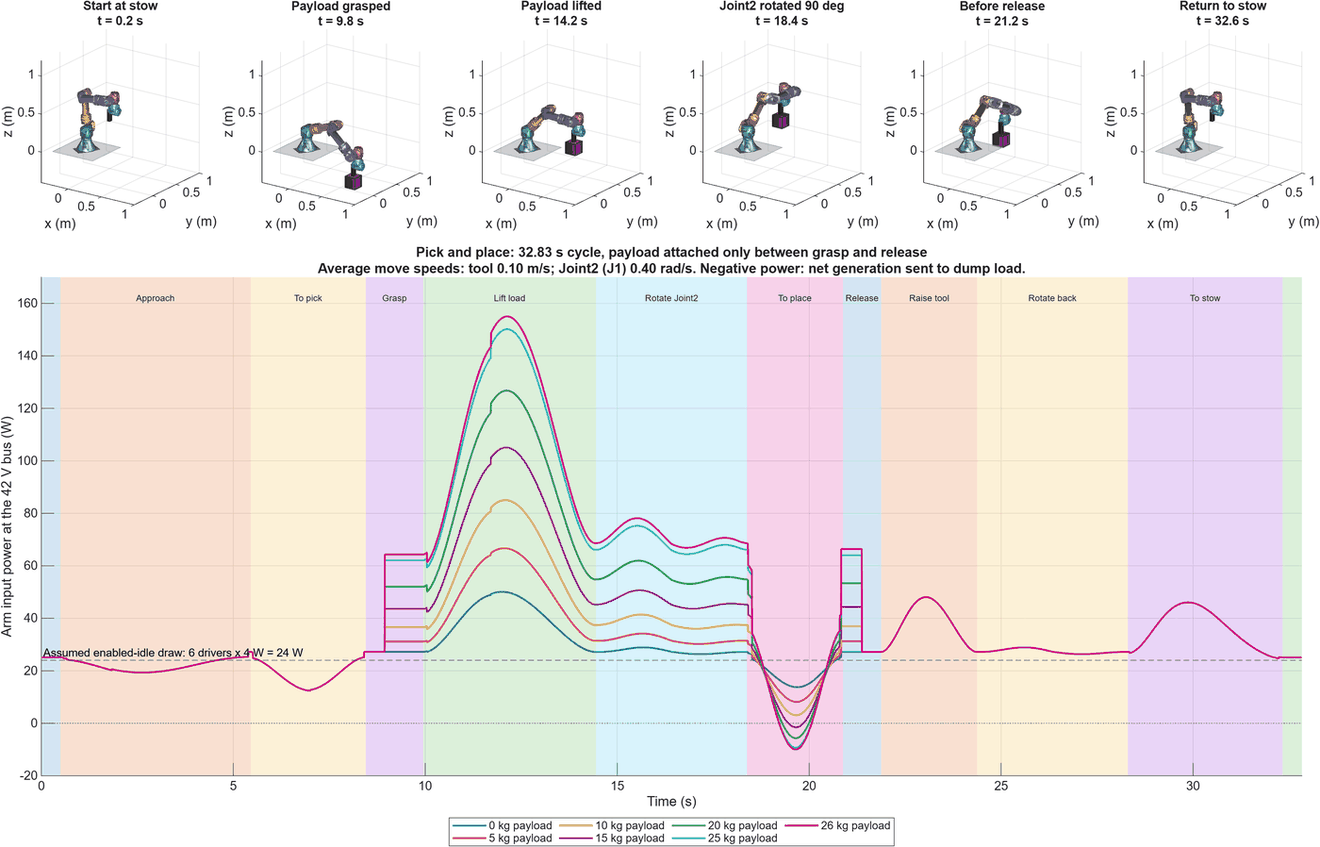
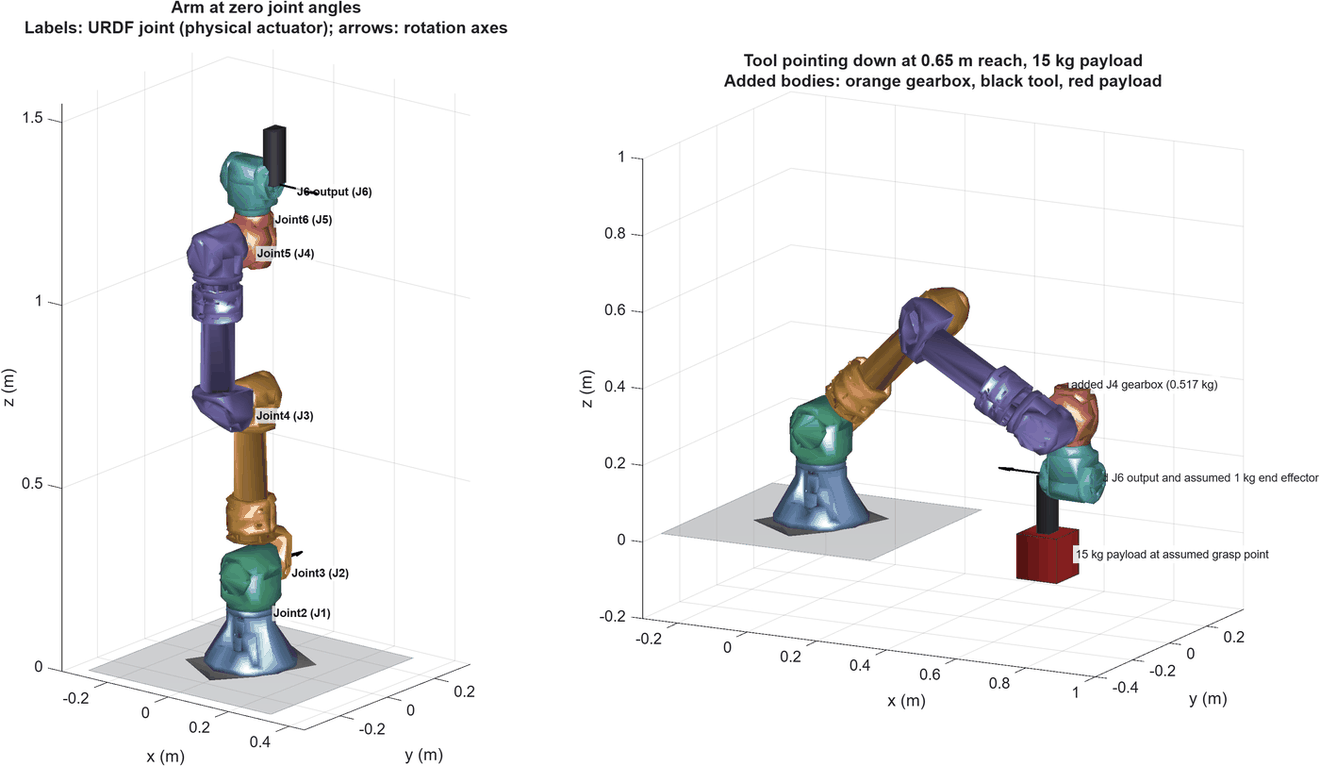
A Simscape Multibody model of the MIRAGE rover's 6-DoF arm, built to size its power system. It runs pick-and-place cycles with payloads from 0 to 26 kg and logs power at each joint and on the bus.
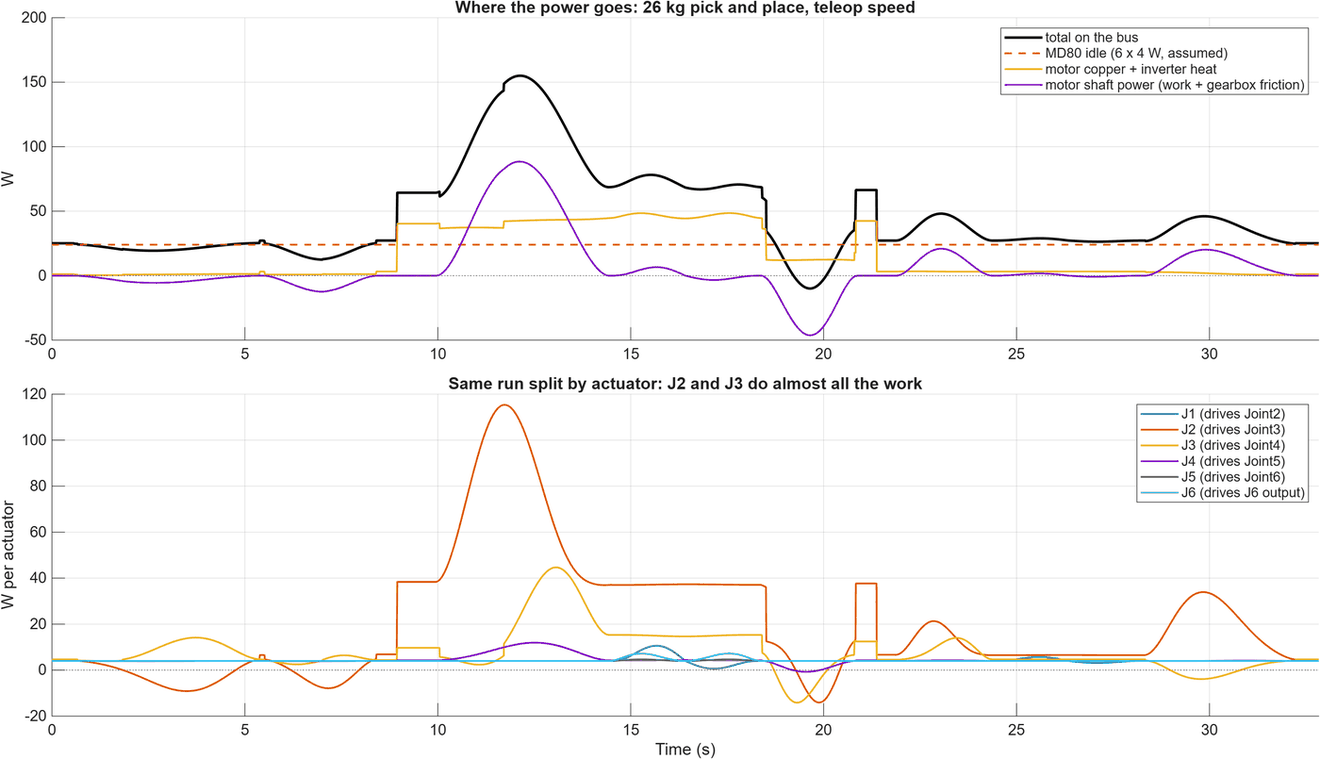
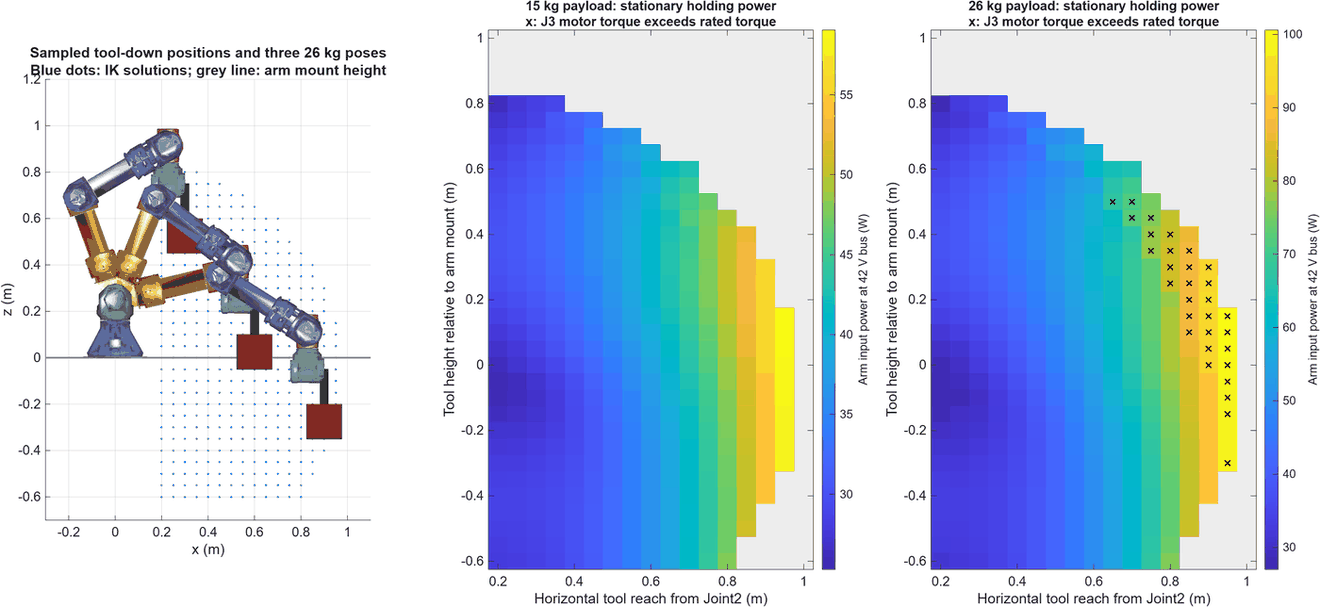
The 26 kg cycle peaks at 155 W on the bus, and two of the six actuators do almost all the work. These are simulation results only, and a few 26 kg poses exceed the J3 motor's rated torque.
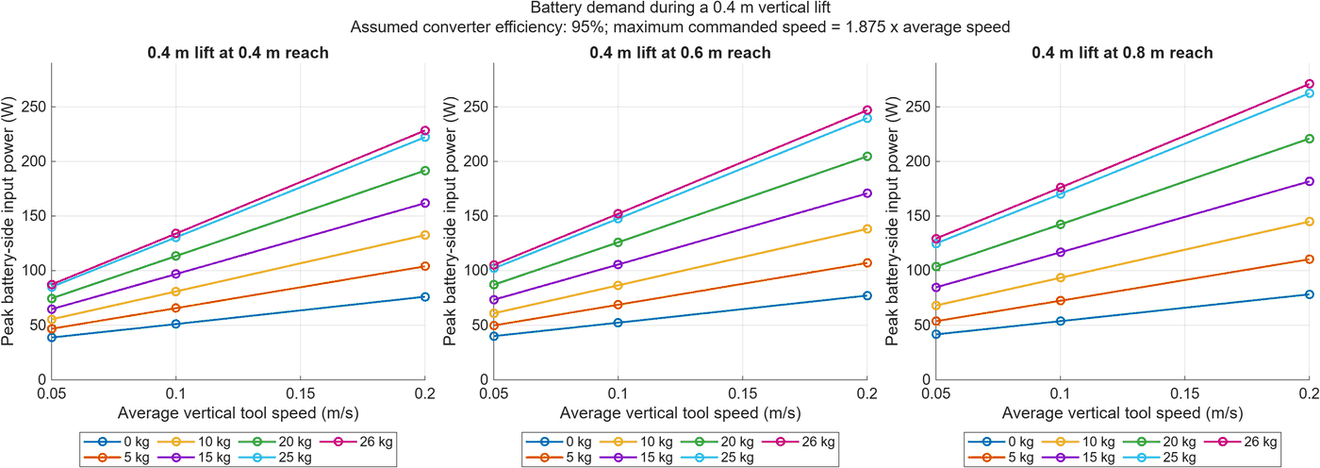
Arm poses through a pick-and-place cycle, and bus power over time for payloads from 0 to 26 kg.Where the power goes in the 26 kg cycle: bus total, then the same run split by actuator.Stationary holding power across the reachable workspace with 15 kg and 26 kg payloads. ✕ marks where the J3 motor exceeds its rated torque.Peak battery-side power for a 0.4 m vertical lift against tool speed, at three reaches.The model at zero joint angles, and reaching 0.68 m with a 15 kg payload.