I designed the third joint of the MIRAGE arm, which connects the arm's first and second carbon-fibre tubes. It's designed to output 50 N·m so the arm can pick up a 5 kg load from over a metre away.
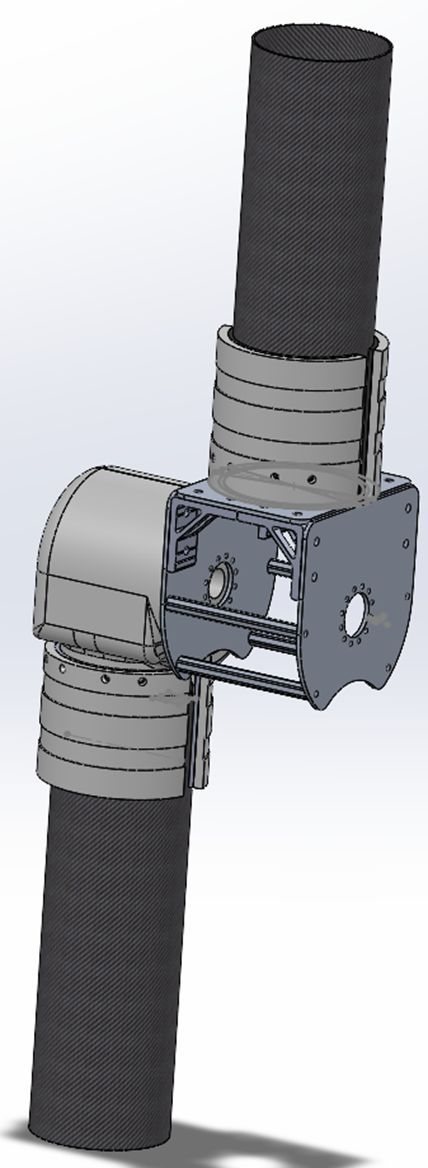
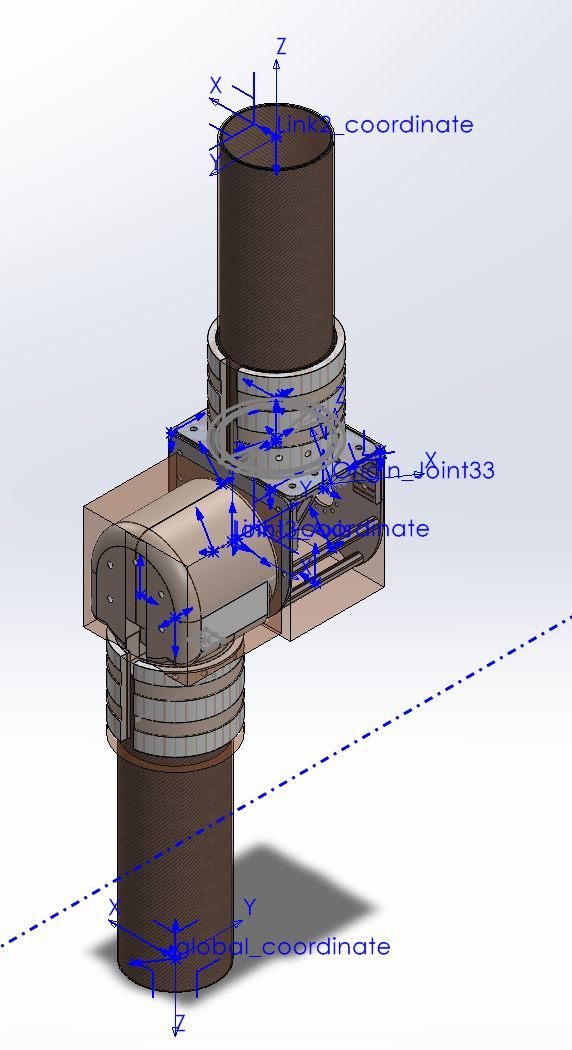
The joint clamps onto the tubes by friction, so there's no drilling into the carbon fibre to weaken it. I also built the joint's URDF model, with collision geometry, for Gazebo simulation.
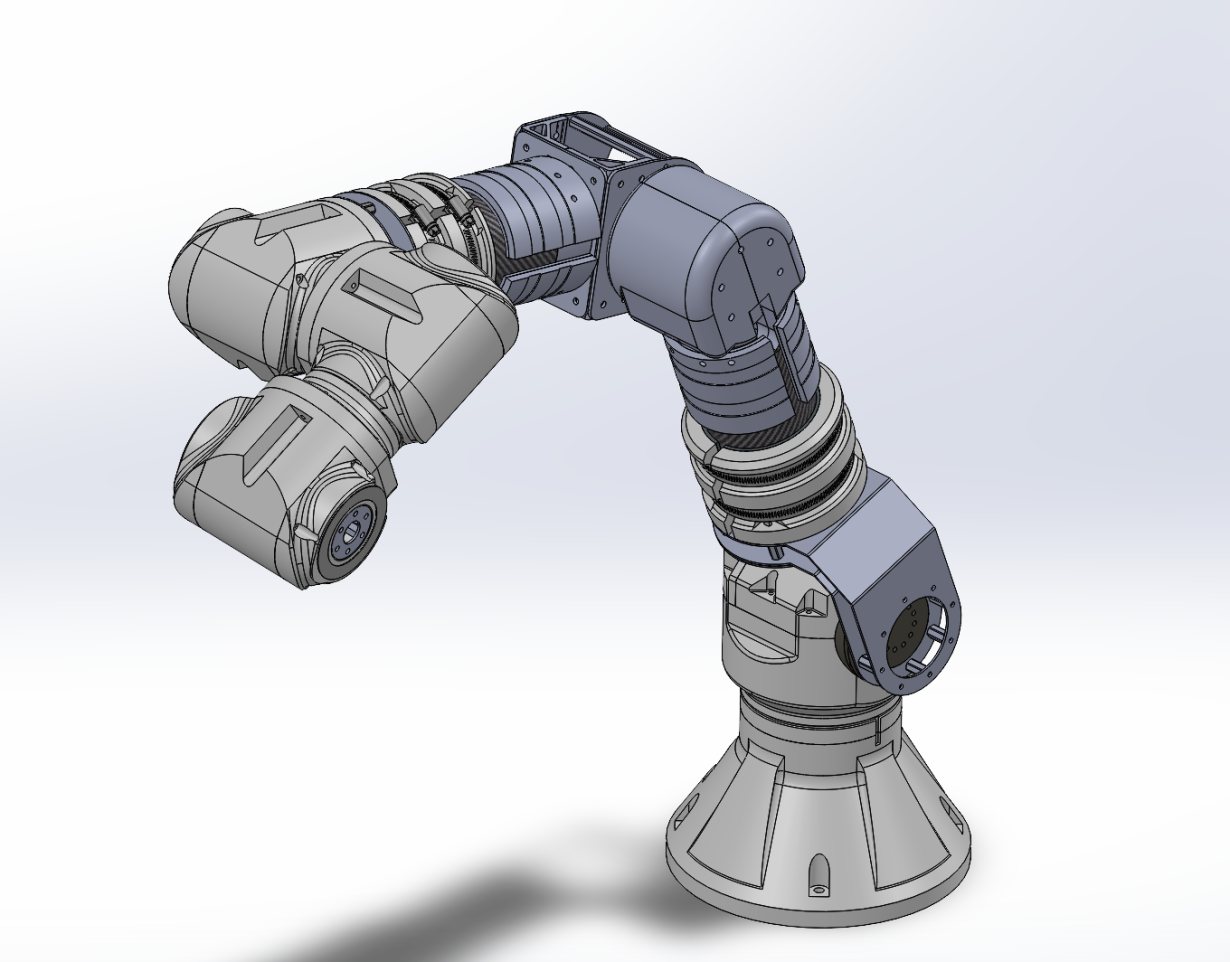
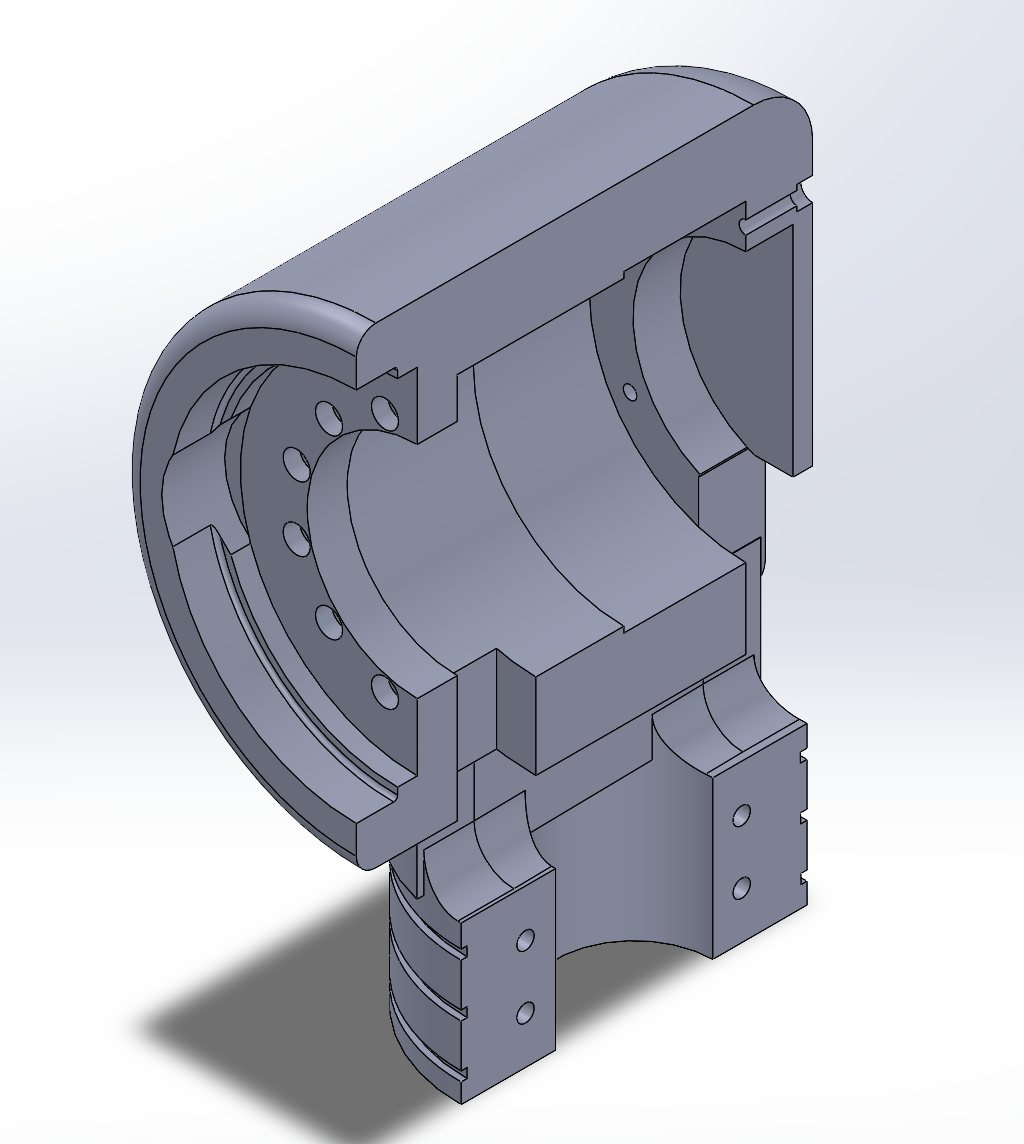
The full 6-DoF MIRAGE arm in SolidWorks, from the base to the wrist.Section view of the joint 3 housing, showing the bore for the actuator and the clamp that grips the tube below.Joint 3 clamped between the arm's two carbon-fibre tubes by friction, with no holes drilled into the carbon.Coordinate frames placed on the joint for the URDF export, used to build the Gazebo model.